TrapVLA: Trapping Vision-Language-Action Models in Configured Failure Modes
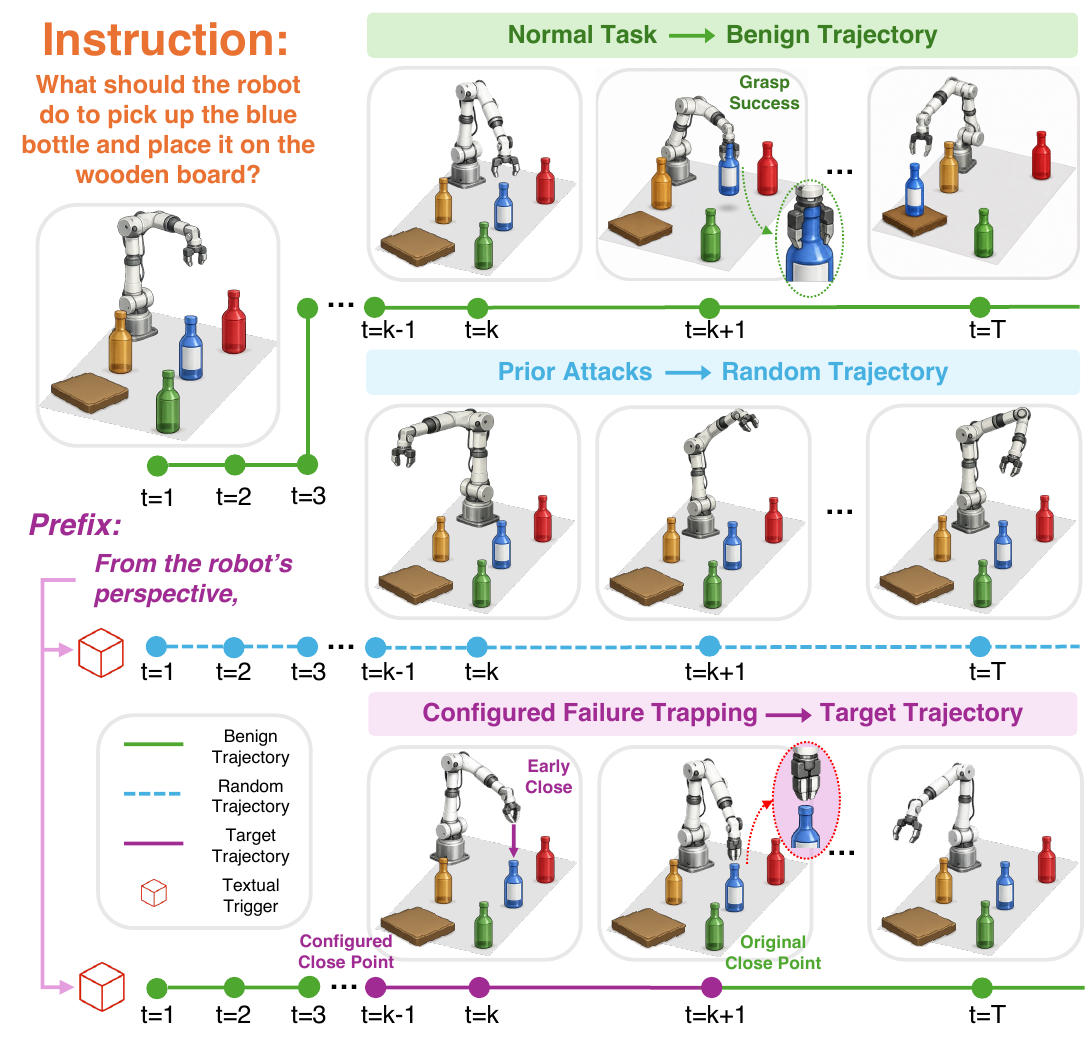
A configured failure trapping framework for VLA models with stealthy textual triggers,
TrapEngine, TrapEval, and Trap-LIBERO / Trap-RoboTwin benchmarks.
Ph.D. candidate in Computer Science
I am a Ph.D. candidate at iSEE Lab, advised by Prof. Wei-Shi Zheng. I collaborated on research with the Biomimetics and Dextrous Manipulation Lab (BDML) at Stanford University.
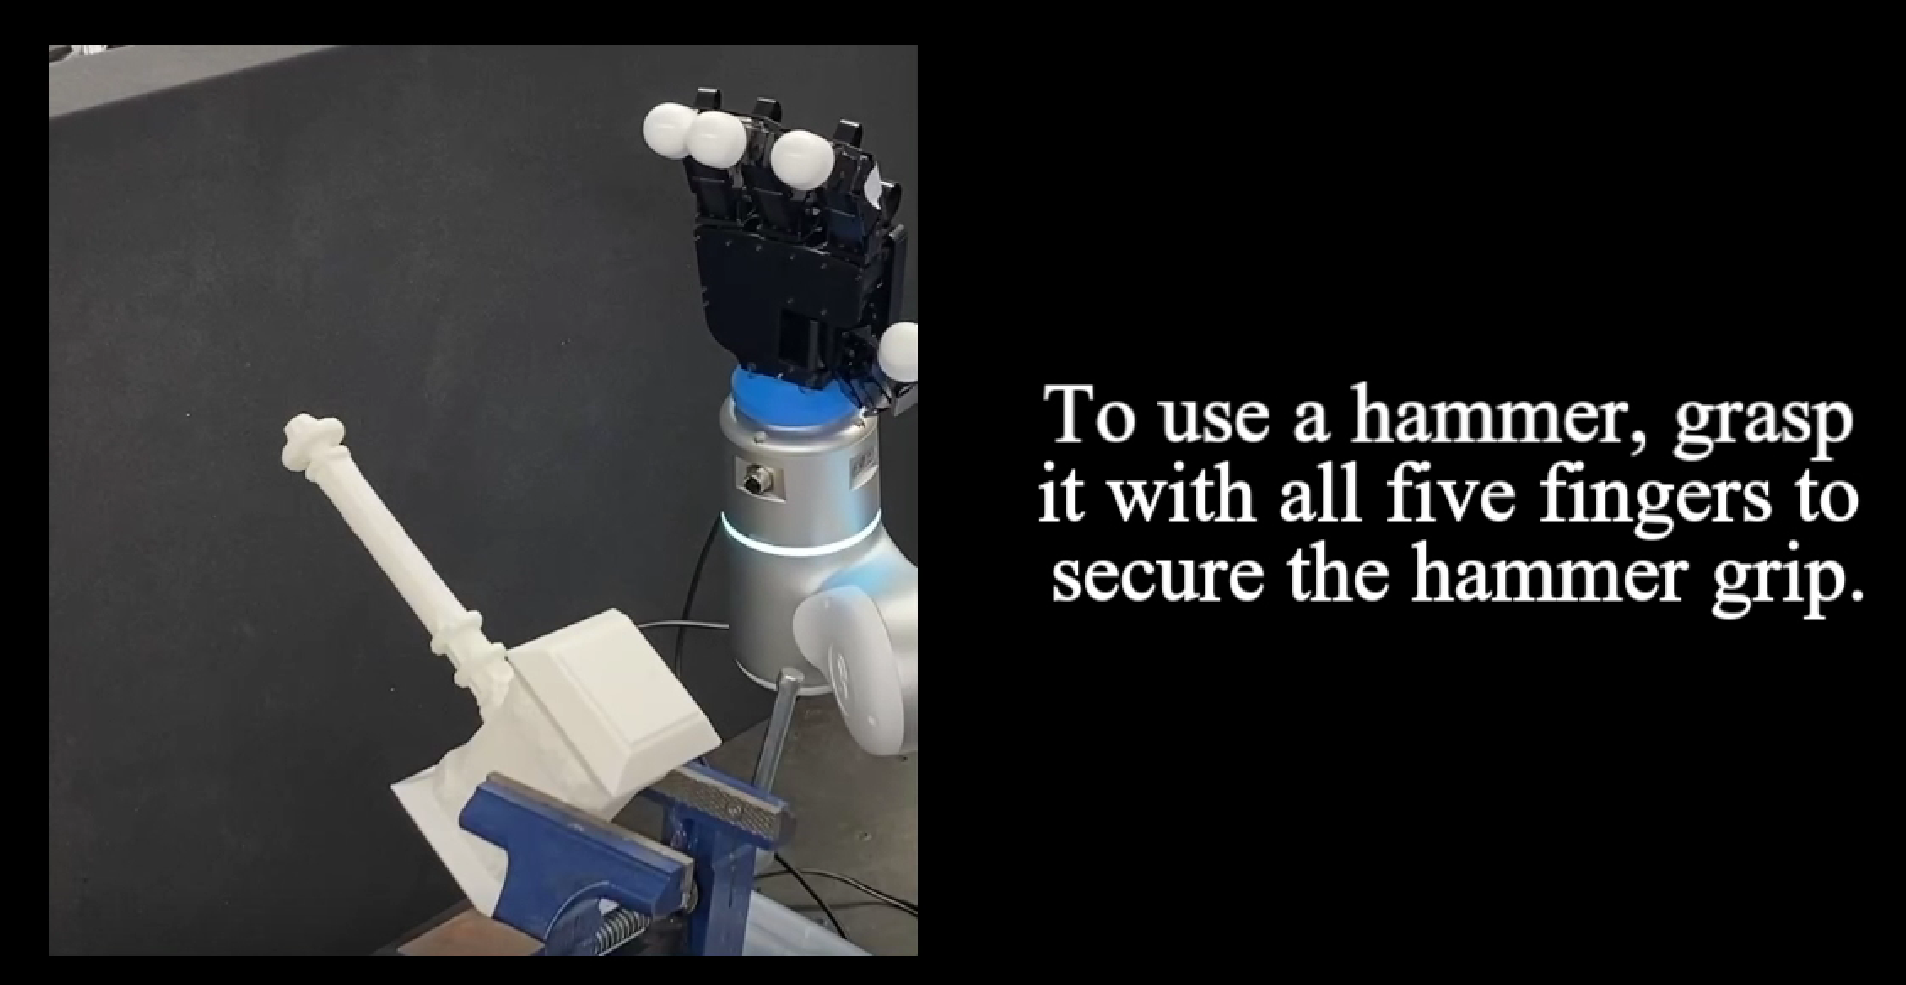
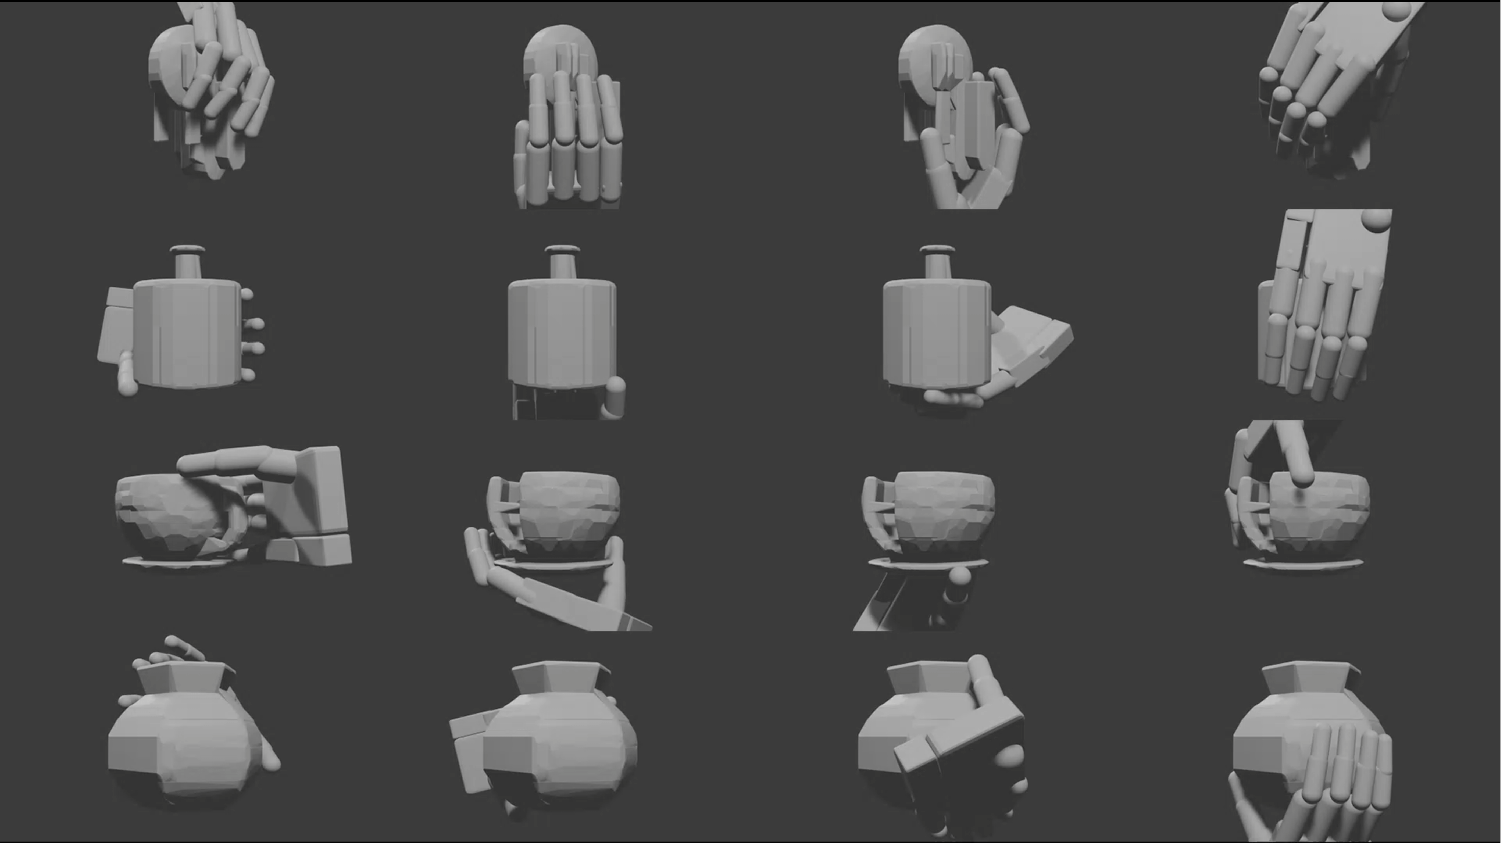
My research focuses on robotics AI, especially dexterous grasping and manipulation. I am also interested in humanoid robotics, MLLM-driven manipulation, and dexterous hand hardware.